
Research
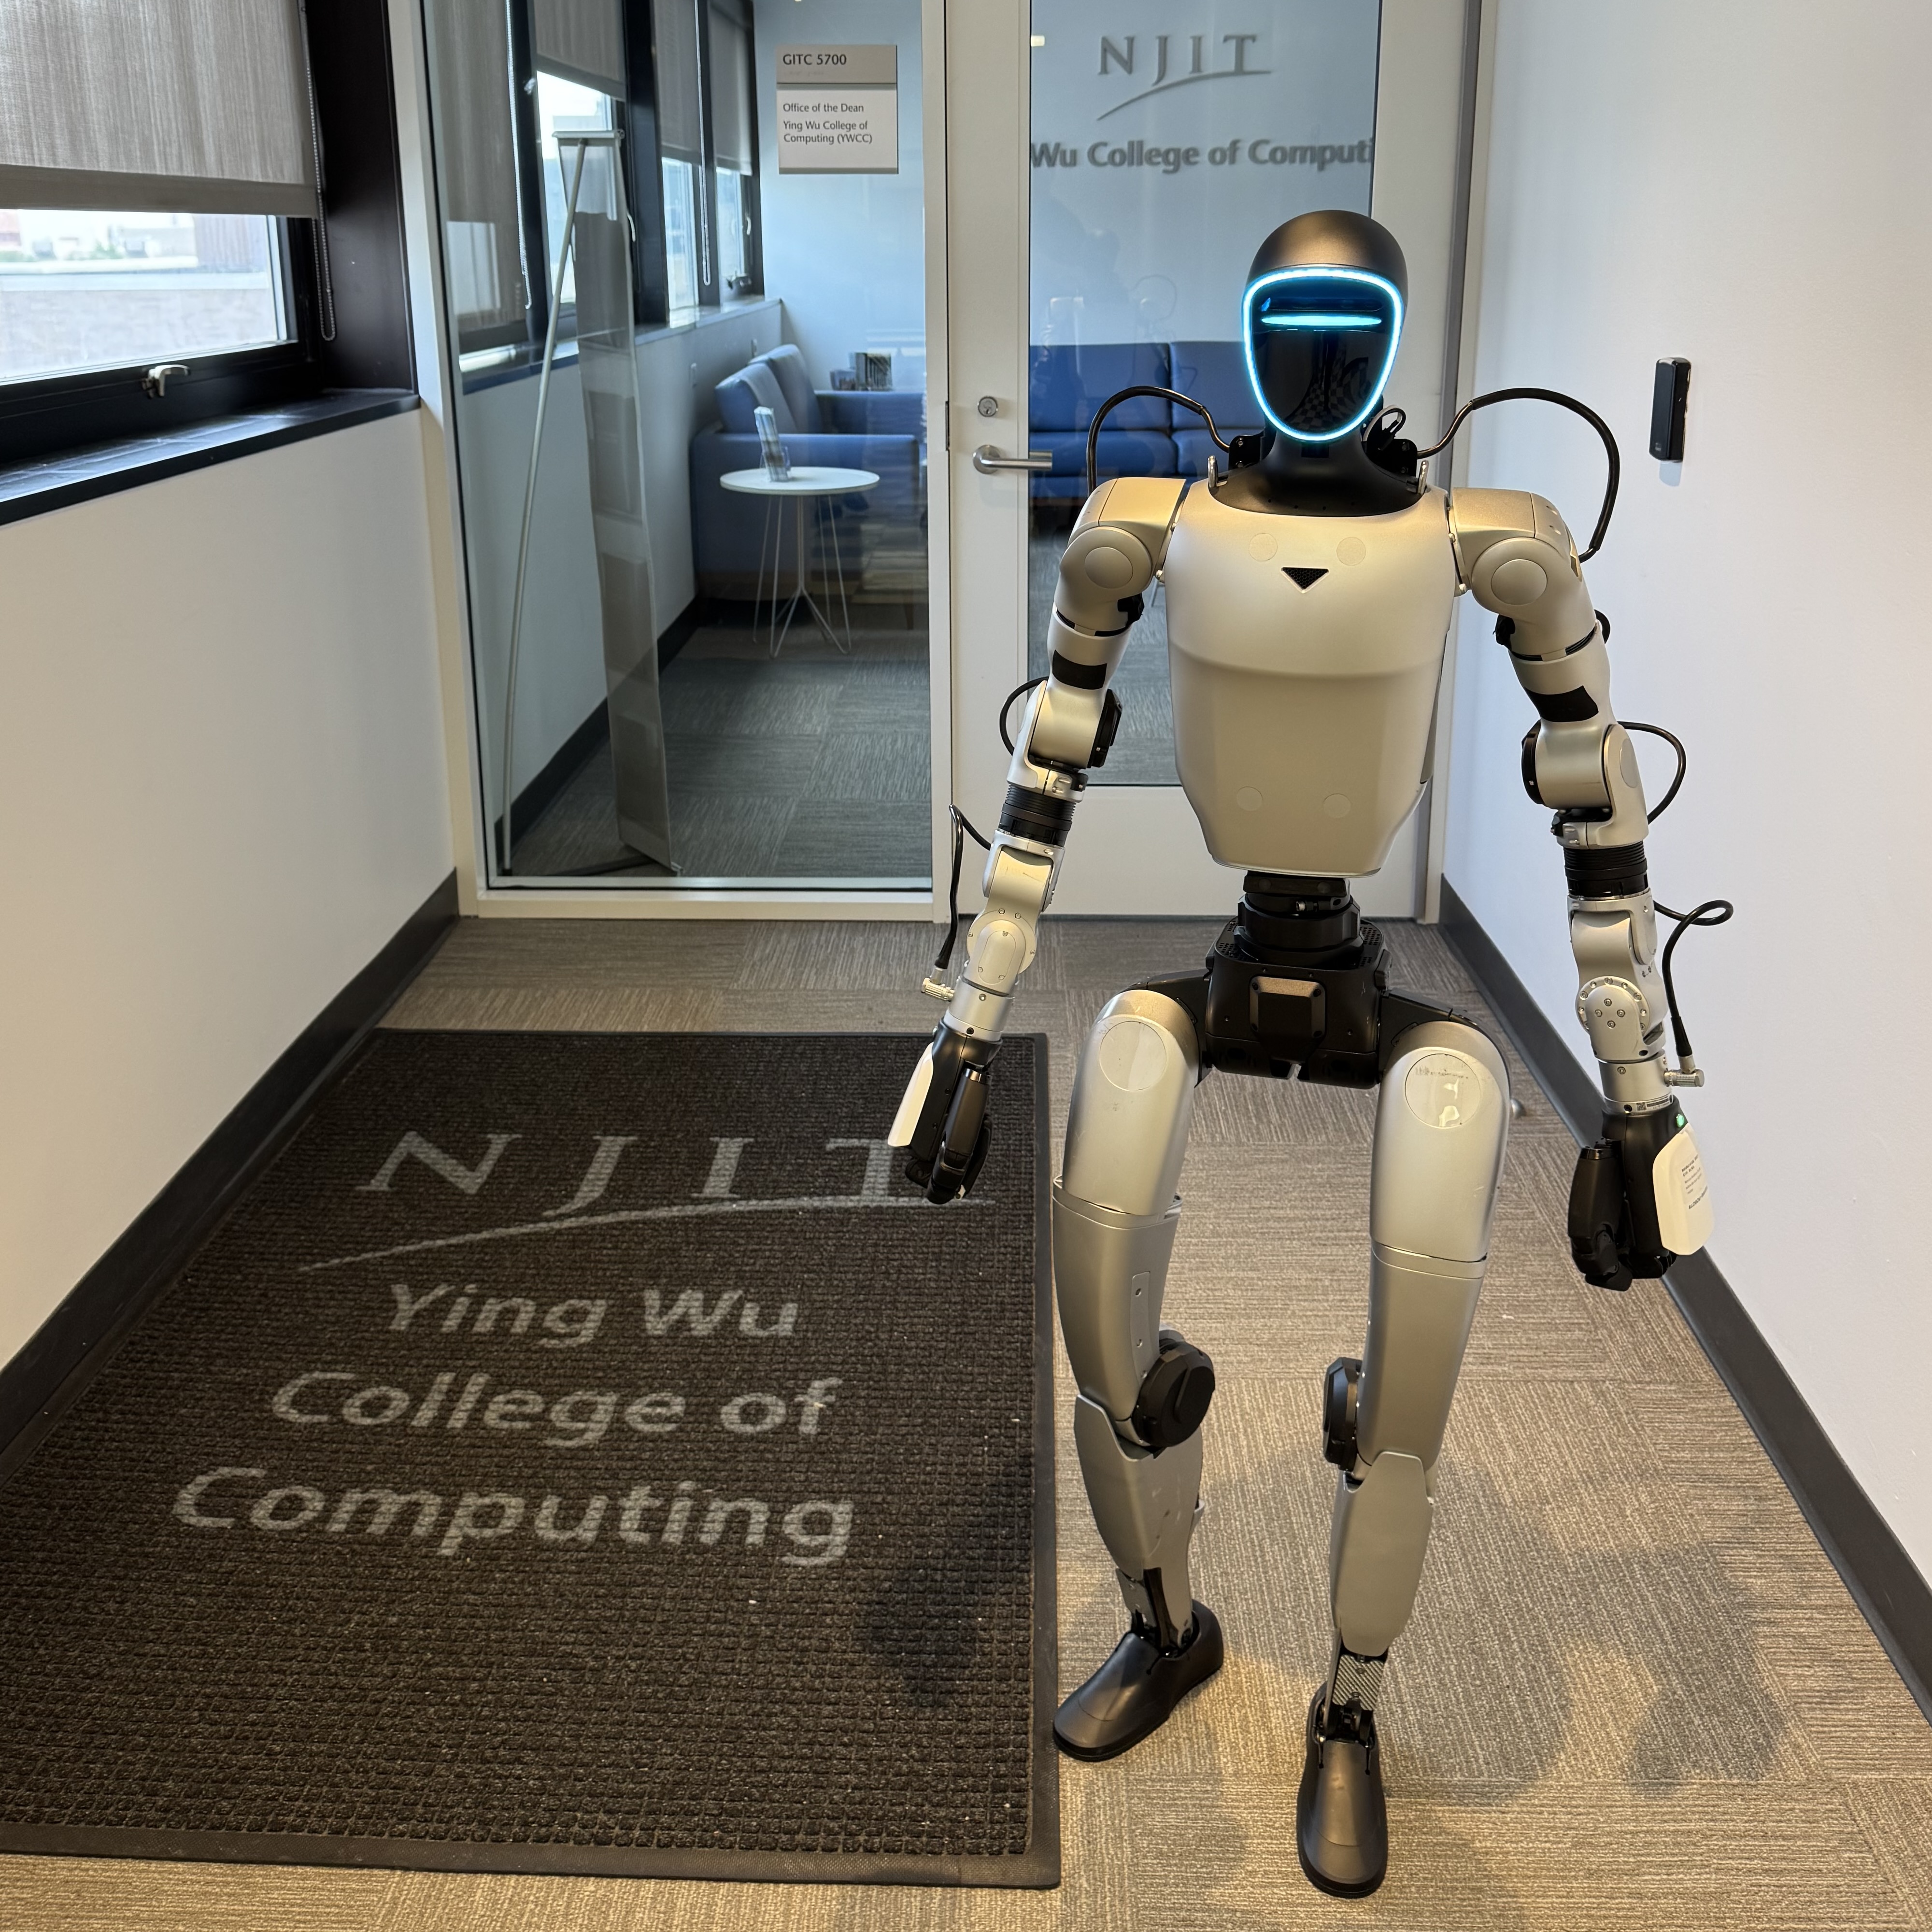
Humanoid Robot Whole-Body Control
Developing intuitive teleoperation, learning, and autonomous control methods that coordinate locomotion, manipulation, balance, and contact.
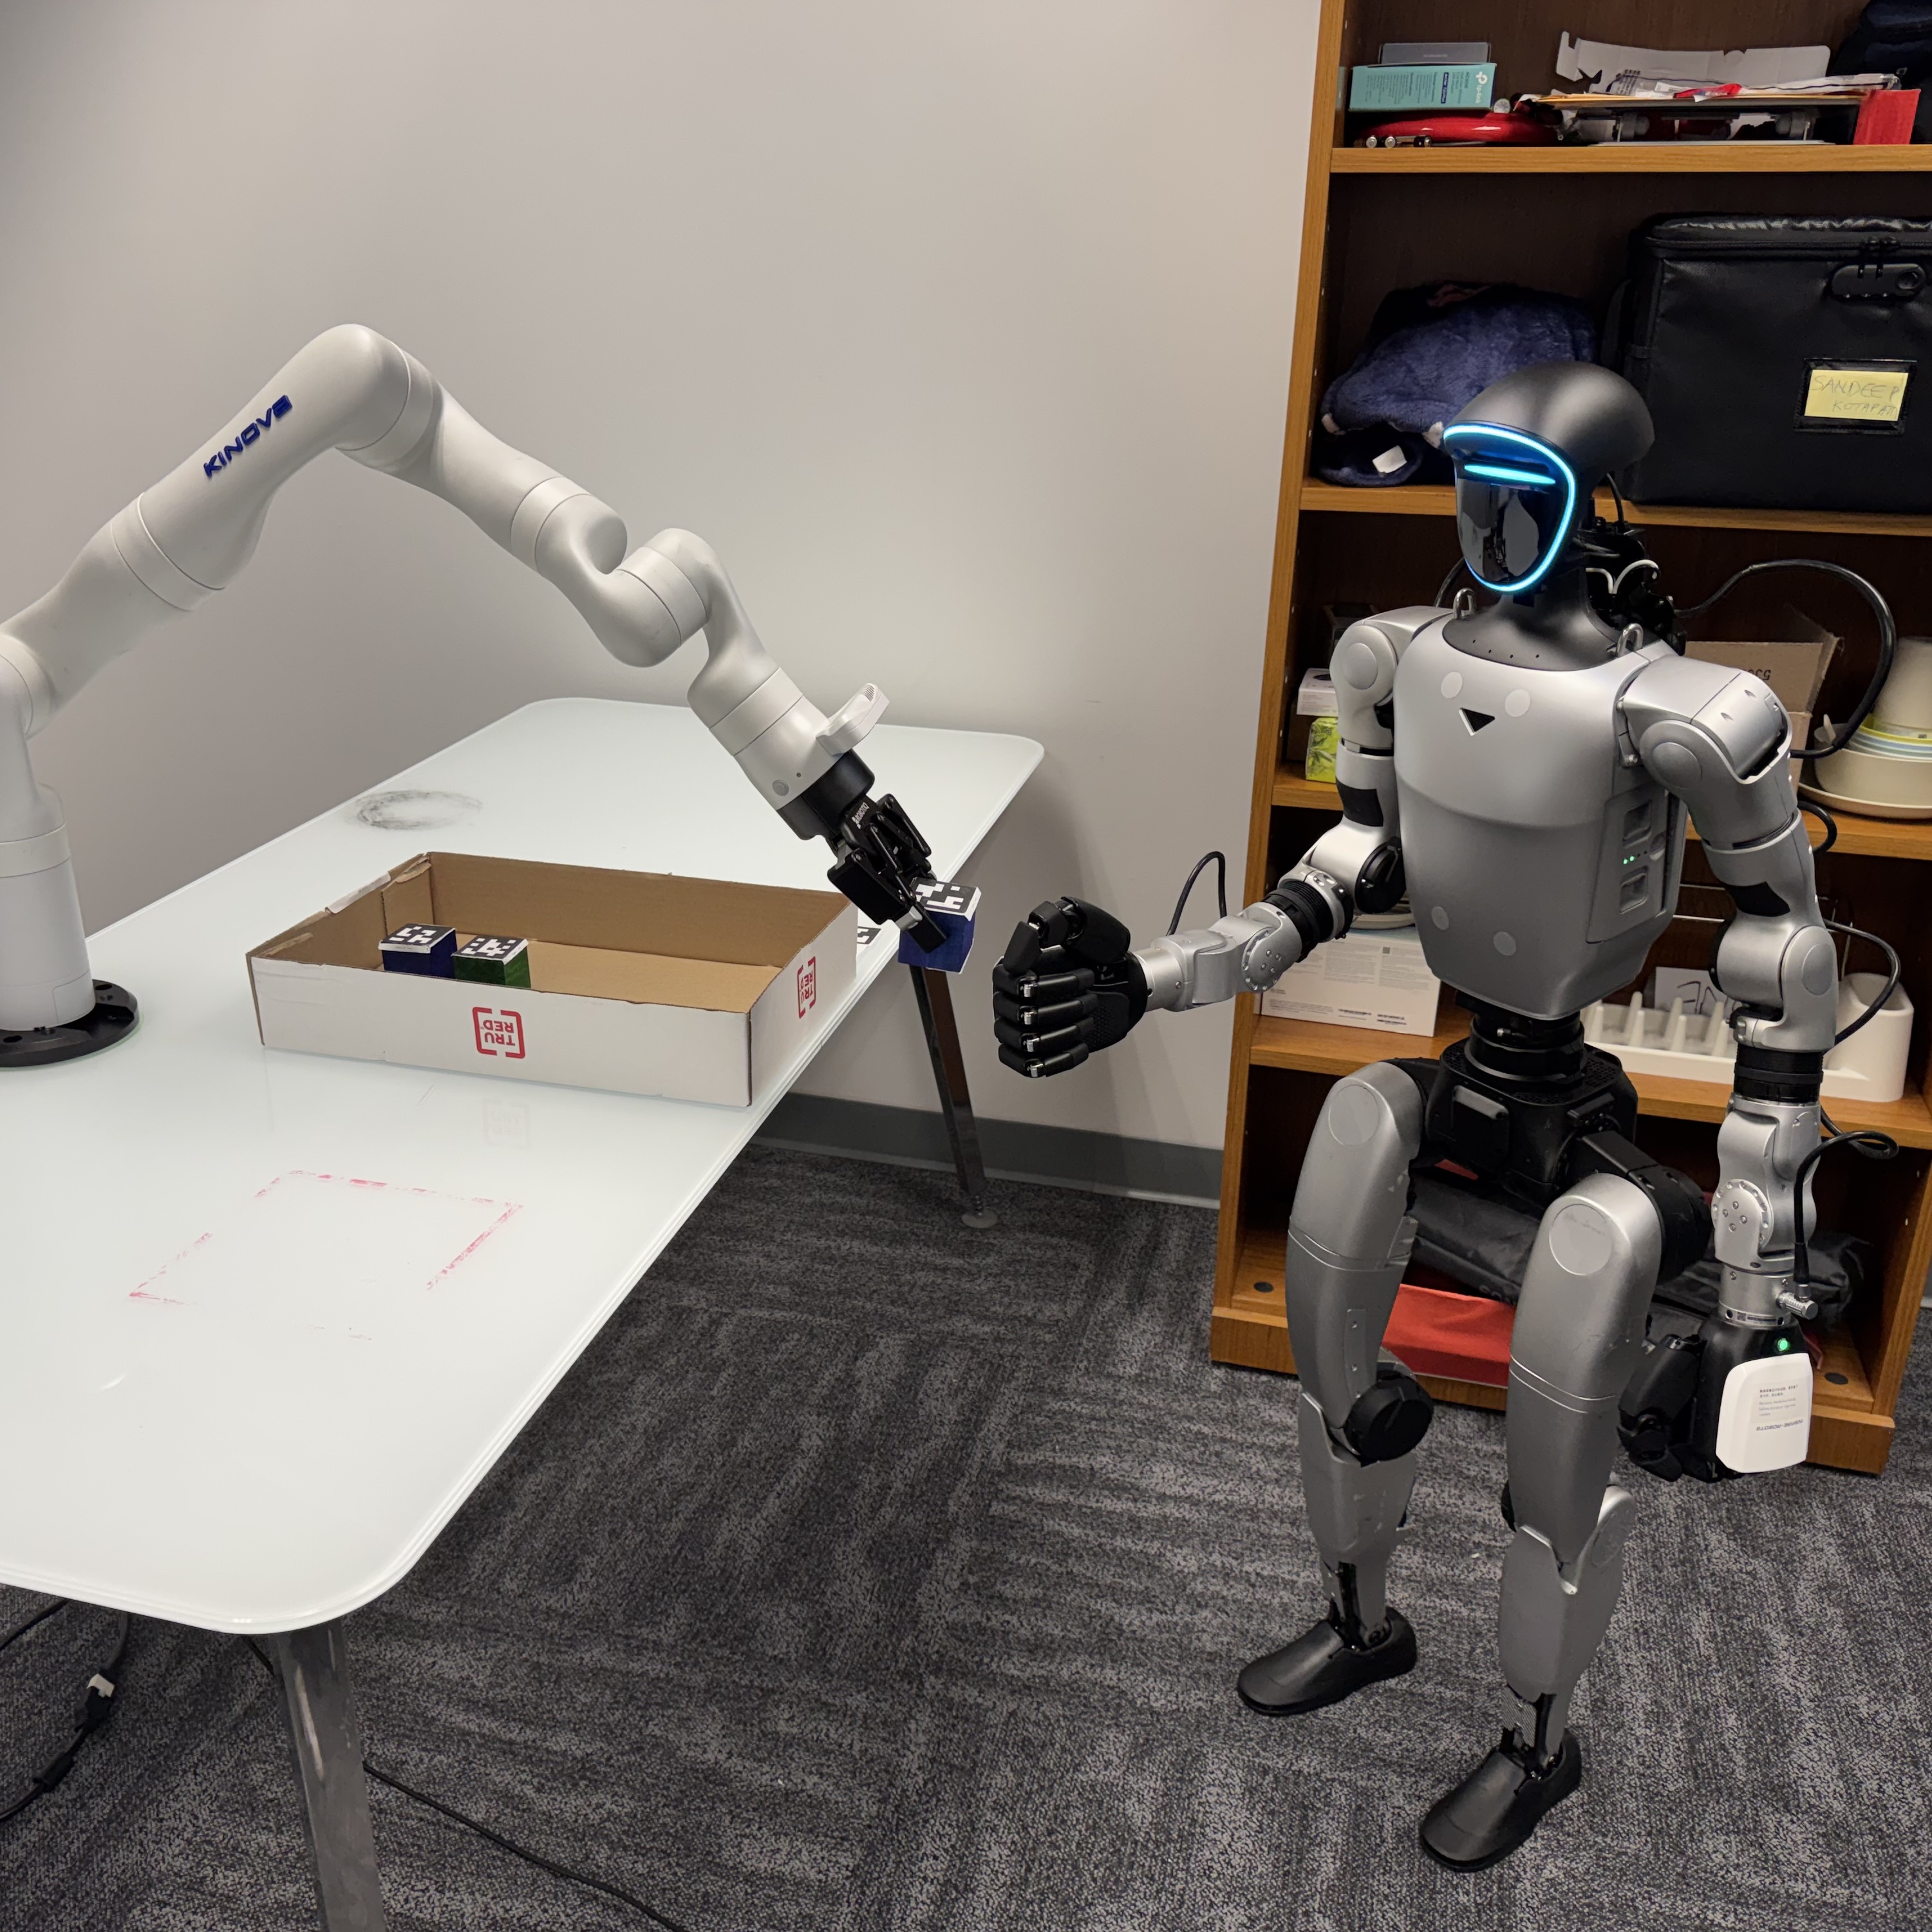
Heterogeneous Robot Teams
Enabling robots with diverse embodiments and capabilities to learn, coordinate, allocate tasks, and recover together in dynamic environments.
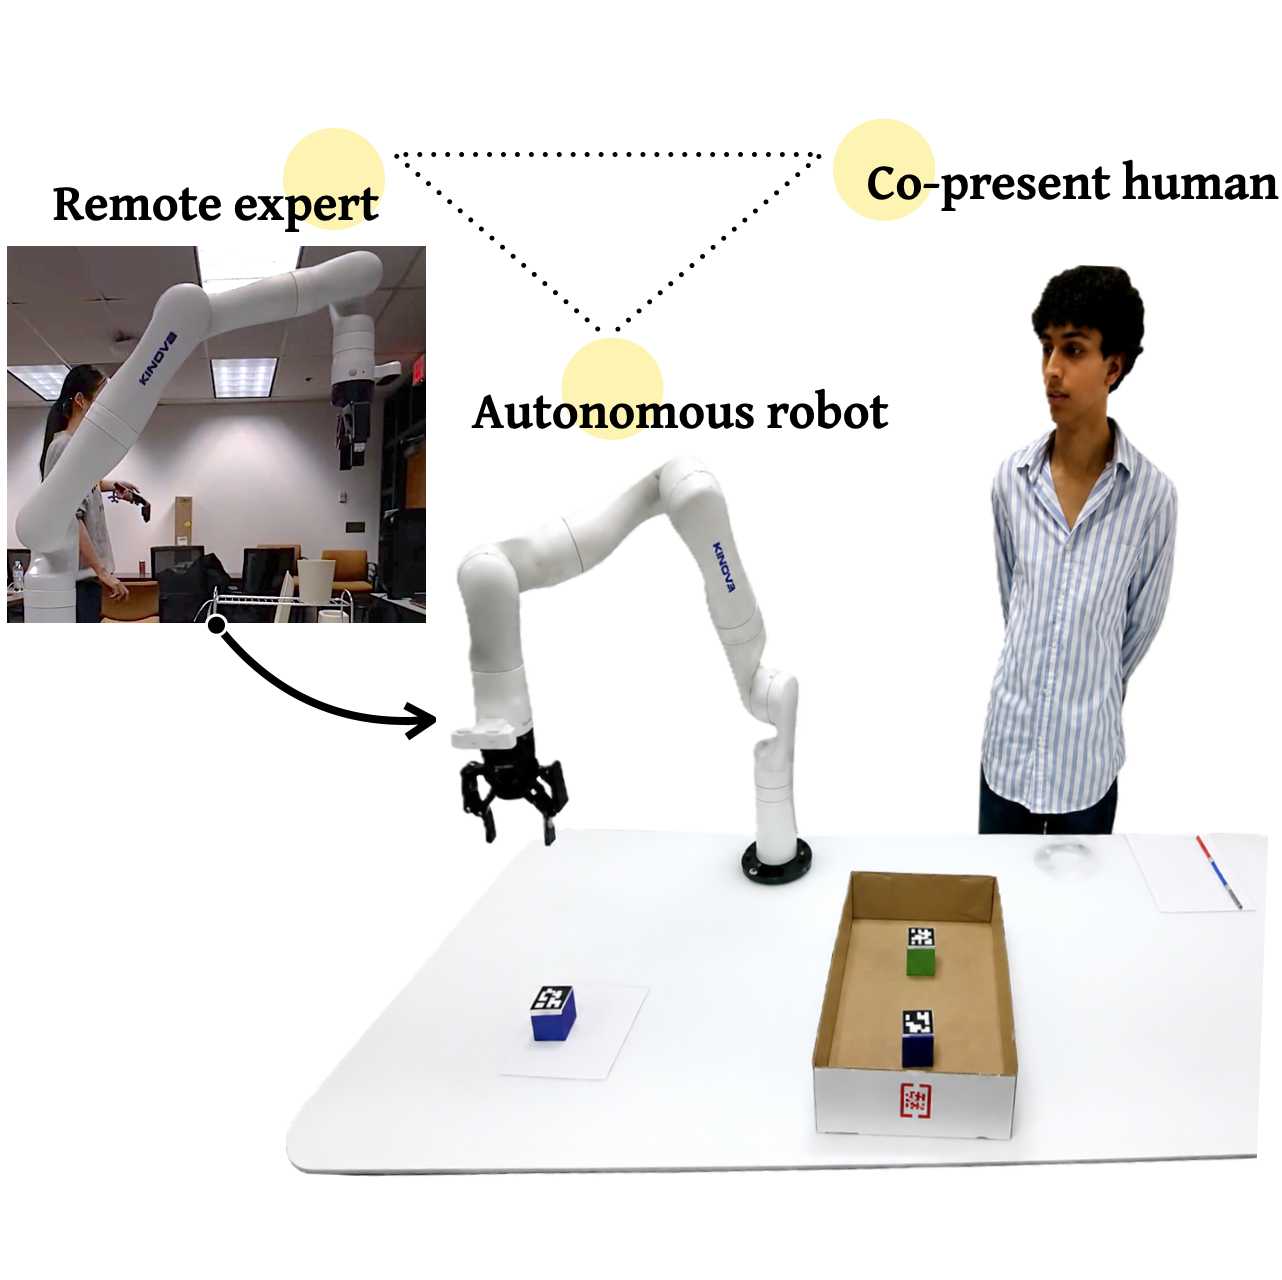
(Multi-)Human–(Multi-)Robot Interaction
Designing and evaluating multimodal interaction and adaptive collaboration methods for teams involving one or more humans and robots.